Research Scientist bridging the gap between mechanical design, control systems, and deep learning to build the next generation of intelligent robotic systems.
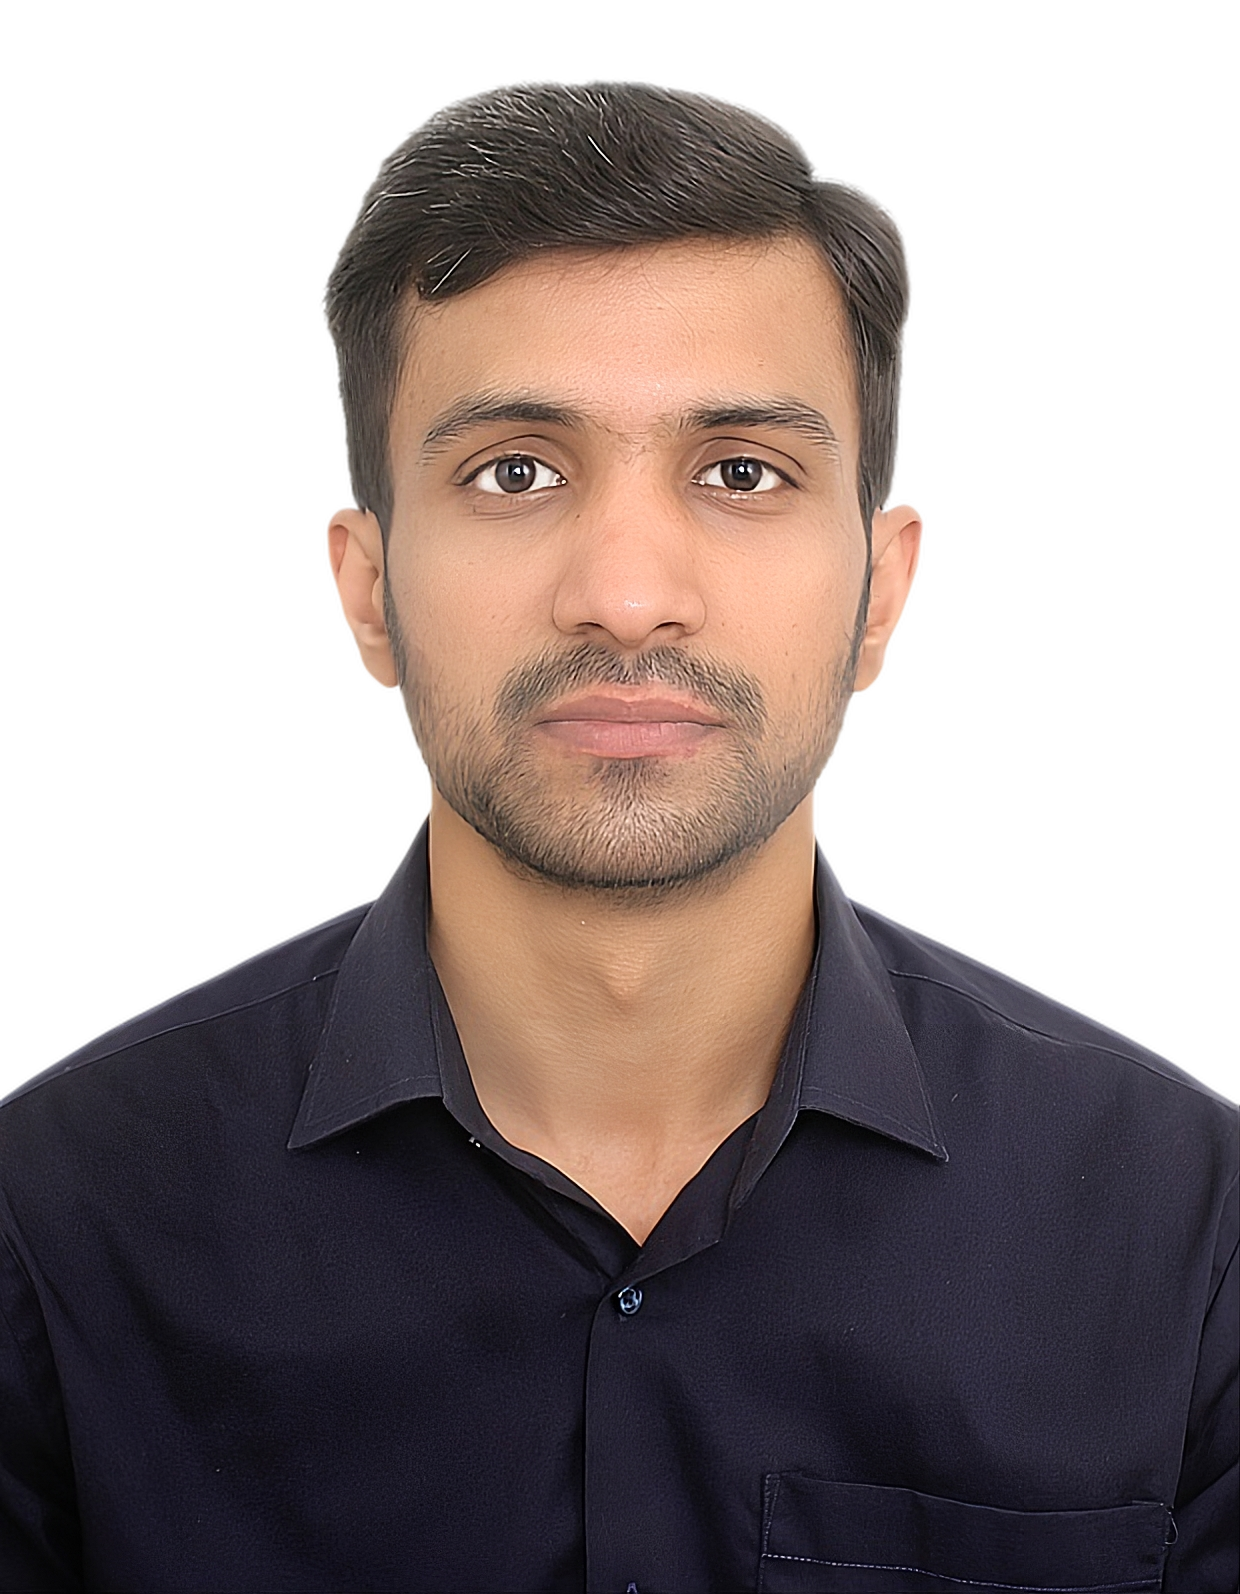
Passionate and driven Mechatronics and Control Engineer with a strong academic background. My expertise spans across diverse engineering fields, including mechanical, electronics, control systems, embedded systems, robotics, computer vision, and machine learning.
My true fascination lies in the domains of control, robotics, computer vision, and machine learning where I aspire to become a dedicated research scientist contributing to cutting-edge technology advancements.
University of Vermont.
UET Lahore (Honours).
Design, Control, Manipulation, Perception and Training. Autonomous Vehicles, Unmanned Aerial Robots.
Robust and Adaptive Control Systems, Non-Linear Control Design for MIMO Systems.
Intelligent Control, Reinforcement Learning, Computer Vision, and Robotic Manipulation.
Low-cost, portable motion capture system for gross motor movement assessment. Uses IR markers, ML models to analyze Bradykinesia.
Simulation of humanoid robot control and path generation employing reinforcement-learning to train the control policy, enabling real-time adaptation.
Differential drive robot with feed-forward neural network and PID control. Employed genetic algorithm to optimize NN parameters for optimized path planning.
S. Husnain and R. Abdulkader
Zarghoon, S. et al., Husnain, S. and Martinez, C.M.
Riaz, M.T., et al., Husnain, S.
I am open to discussing research collaborations, consulting opportunities, or PhD positions in Robotics, Control Systems, and Machine Learning.
+1 (802) 399 0771
+92 (305) 4526 831